Bagel Labs CAREERS

General World
Action Model

Bagel Labs is a physical AI research lab developing world-action models for robot control. We combine compact model architecture with efficient training to accelerate improvement across model generations.

Explore deployment ↓
Read the paper ↗

Training architecture

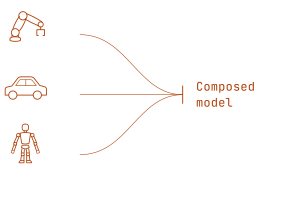
PARIS adapts the topology of training to the distributed structure of the physical world. Specialized models learn independently, then compose into a unified model. This approach yields better results than monolithic training at matched data and compute.

Specialized models for an arm, a car, and a humanoid compose into one model. PARIS trains diffusion experts independently and combines their capabilities through routing. Its separately published studies do not establish robotics performance.

Model architecture

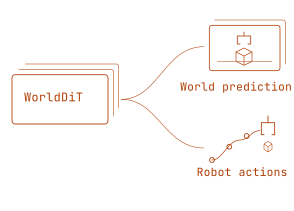
WorldDiT is Bagel Labs’ compact model architecture for robot learning and control. It sits on the reported Pareto frontier for model size and task success. It is the foundation for one model designed to improve across tasks, environments, and robot types.

WorldDiT jointly models future world observations and robot actions. Its reported model-size and task-success evidence comes from LIBERO simulation, not real-robot validation.
Toronto, Canada 9°C

Interested in Bagel Labs’ model for robot control?

We’ll only use your email to follow up.

Please enable JavaScript to submit this form.